HKCLR Manipulation Group

Research

Our research focuses on vision-based robotic manipulation, embodied AI, and learning-based control for real-world robotic systems. We aim to develop robotic systems that can perceive, reason, and interact robustly with complex and unstructured environments.

Highlighted
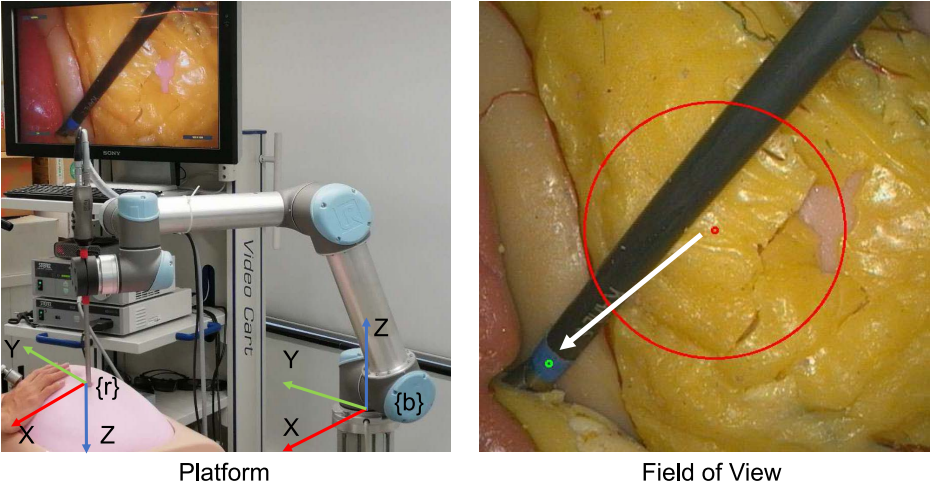
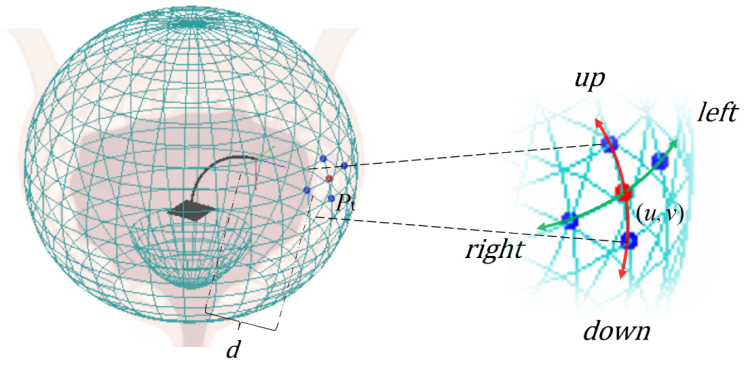
Adaptive FOV Control of Laparoscopes with Programmable Composed Constraints
Bohan Yang, Wei Chen, Zerui Wang, Yiang Lu, Jiayue Mao, Hesheng Wang, Yun-Hui Liu
IEEE Transactions on Medical Robotics and Bionics · 2019

All

2025

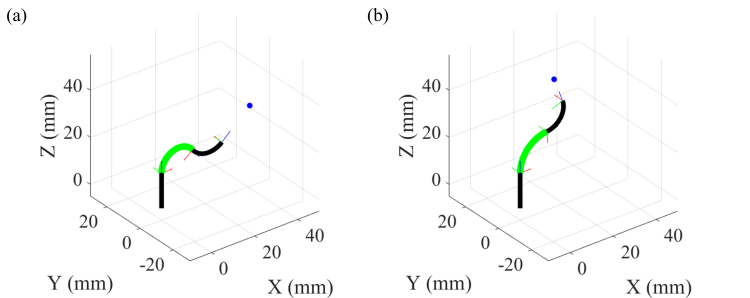
Adaptive Vision-Based Control for Flexible Robot with Unknown Environmental Constraints
Wei Chen, Haiwen Wu, Bohan Yang, Jinfei Hu, Yun-Hui Liu
IEEE International Conference on Real-time Computing and Robotics (RCAR) · 2025
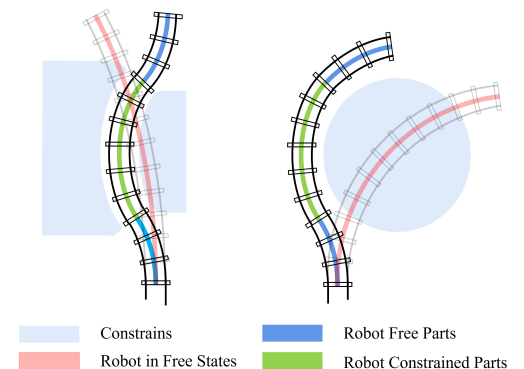
Data-driven Visual Servoing of Flexible Continuum Robots in Constrained Environments
Wei Chen, Haiwen Wu, Xiyue Dong, Bohan Yang, Yun-Hui Liu
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) · 2025

2024

Intuitive Teleoperation Control for Flexible Robotic Endoscopes Under Unknown Environmental Interferences
Wei Chen, Yiang Lu, Bin Li, Jianshu Zhou, Hanwen Cao, Fei Chen, Yun-Hui Liu
2024 IEEE 18th International Conference on Control & Automation (ICCA) · 2024
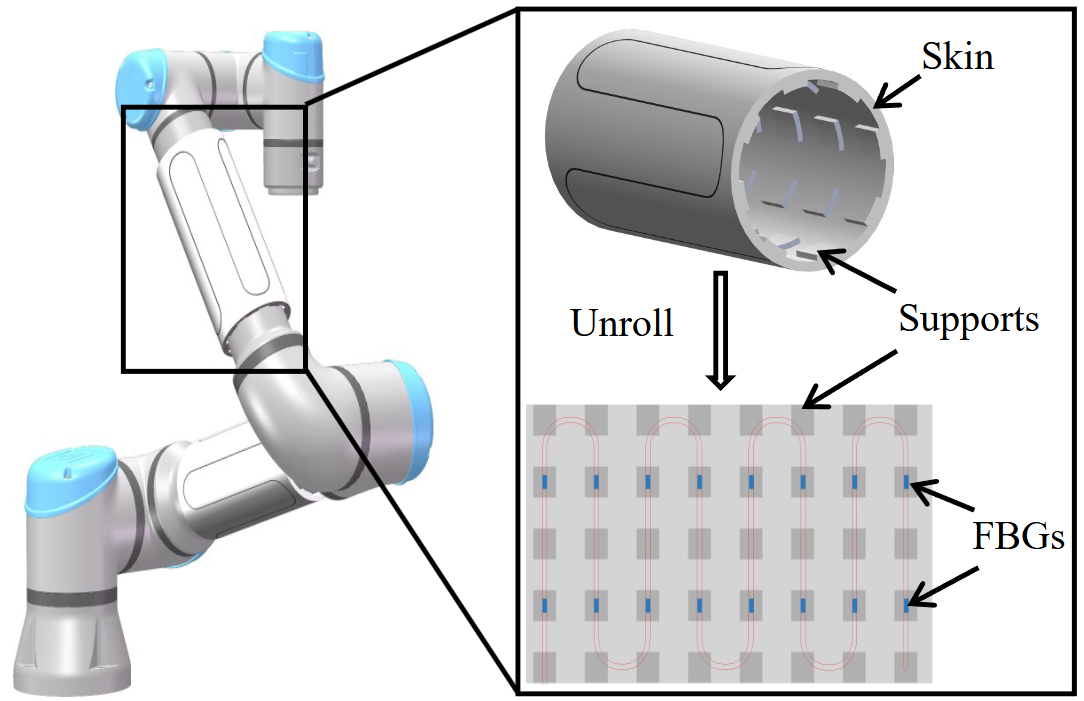
A Robotic Skin Using Low-density FBGs for Human-robot Interaction
Xiyue Dong, Chin-Kiu Lam, Wei Chen, Bohan Yang, Yun-Hui Liu
IEEE International Conference on Robotics and Biomimetics (ROBIO) · 2024

2023

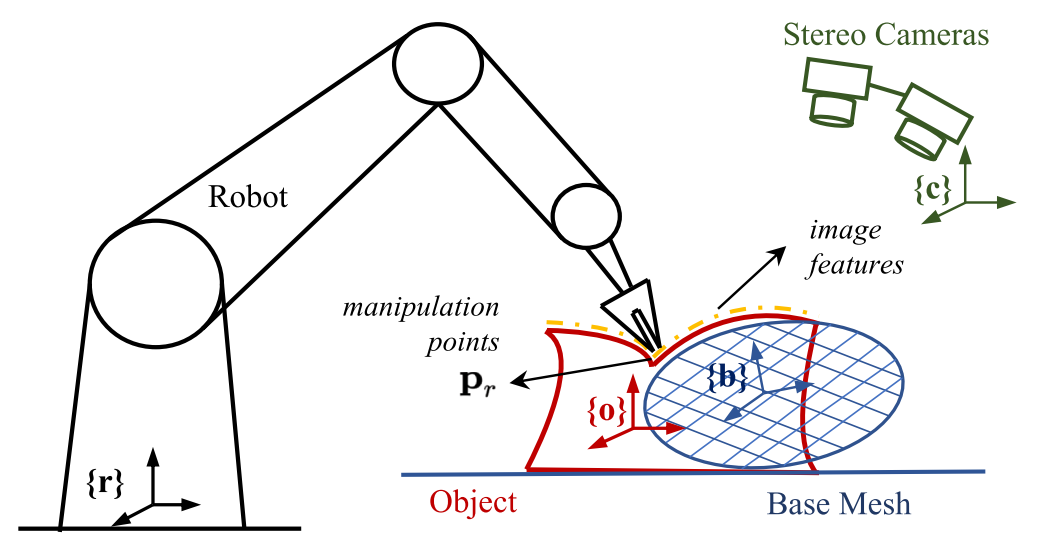
Model-Free 3-D Shape Control of Deformable Objects Using Novel Features Based on Modal Analysis
Bohan Yang, Bo Lu, Wei Chen, Fangxun Zhong, Yun-Hui Liu
IEEE Transactions on Robotics · 2023

2022

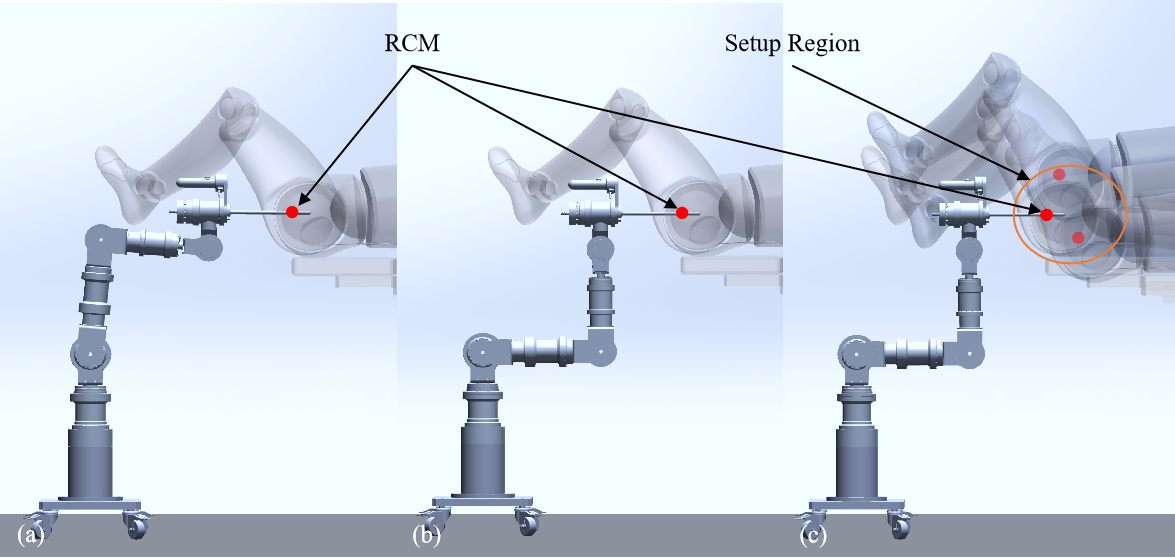
Configurability Selection of Robotic Arm with Constrained Task and Environment in Laparoscopic Hysterectomy for Uterus Manipulation
Wei Chen, Jiahao Wu, Jianshu Zhou, Hesheng Wang, Yudong Wang, Tak Hong Cheung, Yun-Hui Liu
IEEE International Conference on Real-time Computing and Robotics (RCAR) · 2022

2021

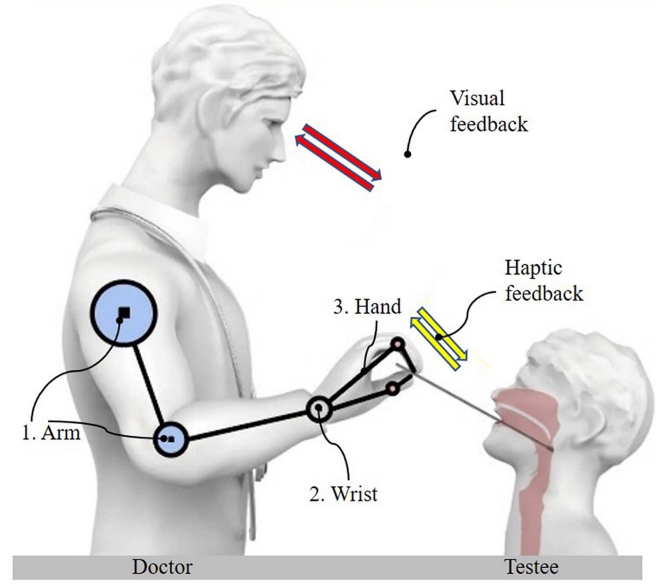
Tele-Operated Oropharyngeal Swab (TOOS) Robot Enabled by TSS Soft Hand for Safe and Effective Sampling
Wei Chen, Jianshu Zhou, Shing Shin Cheng, Yiang Lu, Fangxun Zhong, Yuan Gao, Yaqing Wang, Lingbin Xue, Michael C. F. Tong, Yun-Hui Liu
IEEE Transactions on Medical Robotics and Bionics · 2021

2019

Adaptive FOV Control of Laparoscopes with Programmable Composed Constraints
Bohan Yang, Wei Chen, Zerui Wang, Yiang Lu, Jiayue Mao, Hesheng Wang, Yun-Hui Liu
IEEE Transactions on Medical Robotics and Bionics · 2019