Adaptive Vision-Based Control for Flexible Robot with Unknown Environmental Constraints
Abstract
This paper presents an adaptive vision-based control framework for flexible robots operating under unknown environmental constraints. The proposed method integrates real-time visual sensing and adaptive control strategies to estimate environmental geometry and robot deformation online. By leveraging vision-based pose and shape estimation, the robot achieves robust task execution without prior knowledge of environmental constraints.
Method Overview
We propose a vision-based adaptive control framework that tightly couples real-time visual perception with online deformation and constraint estimation. The controller adapts robot motion in response to estimated environmental geometry without requiring prior models.
Results
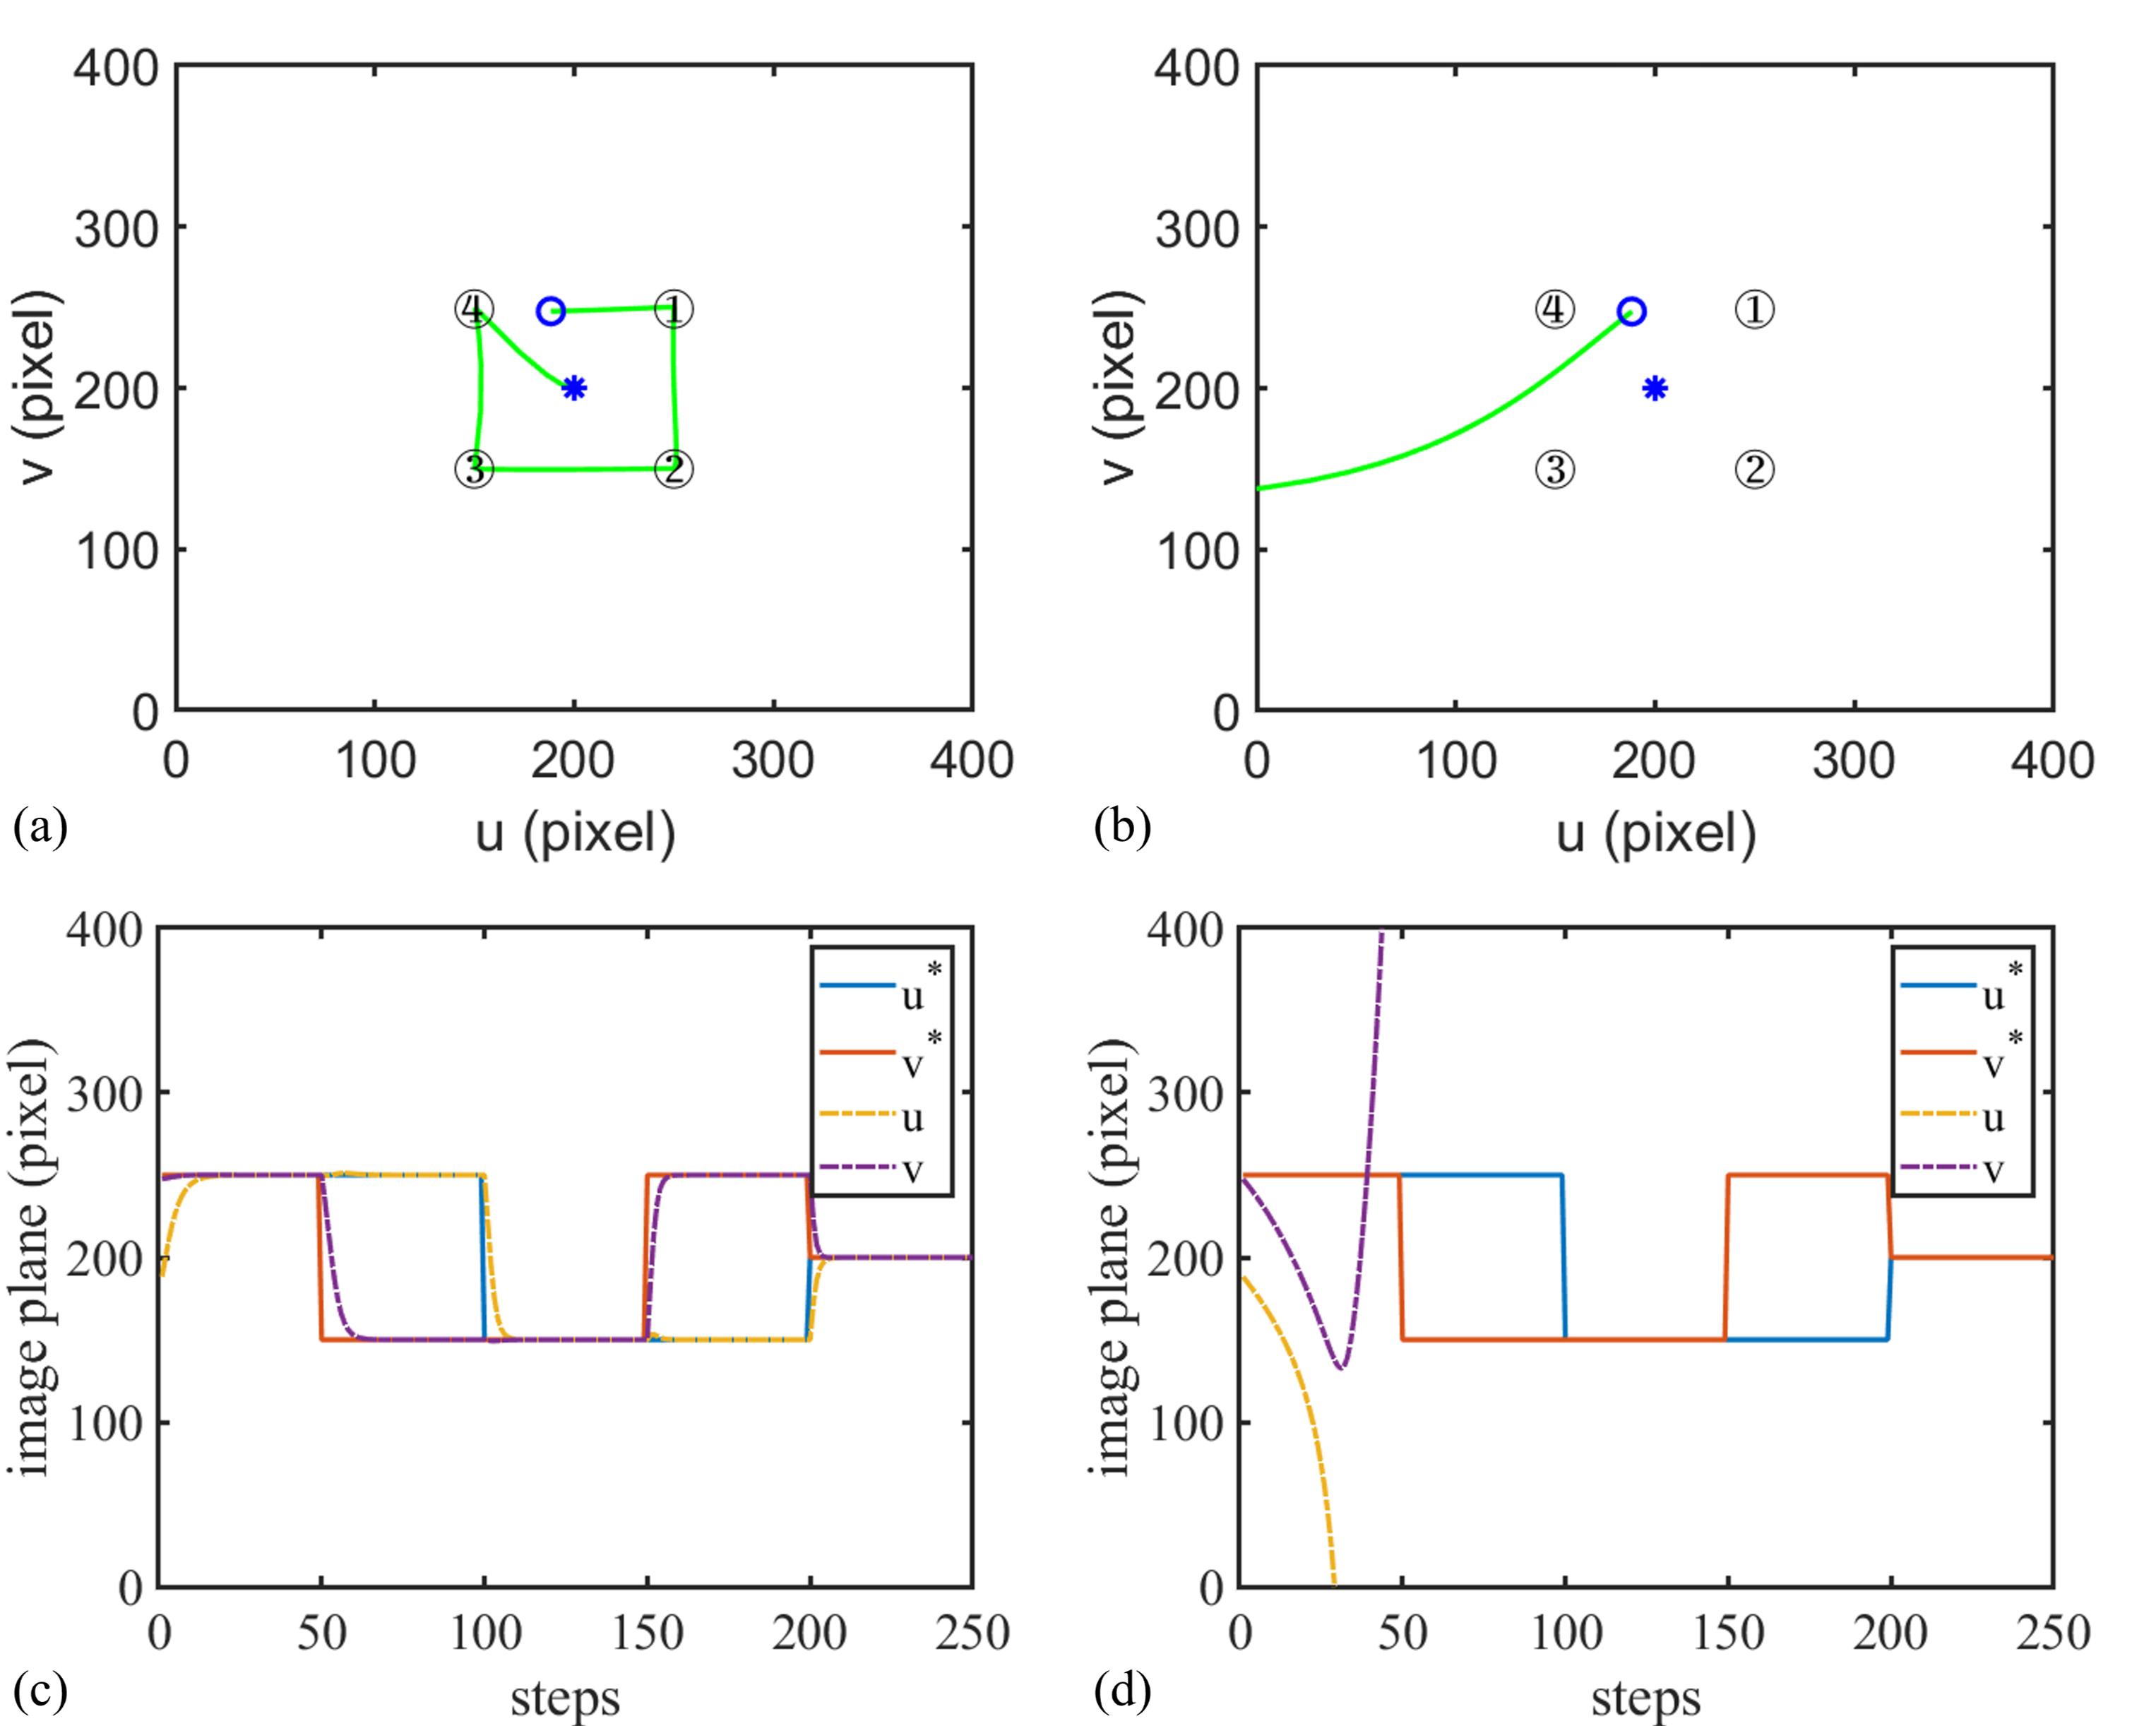
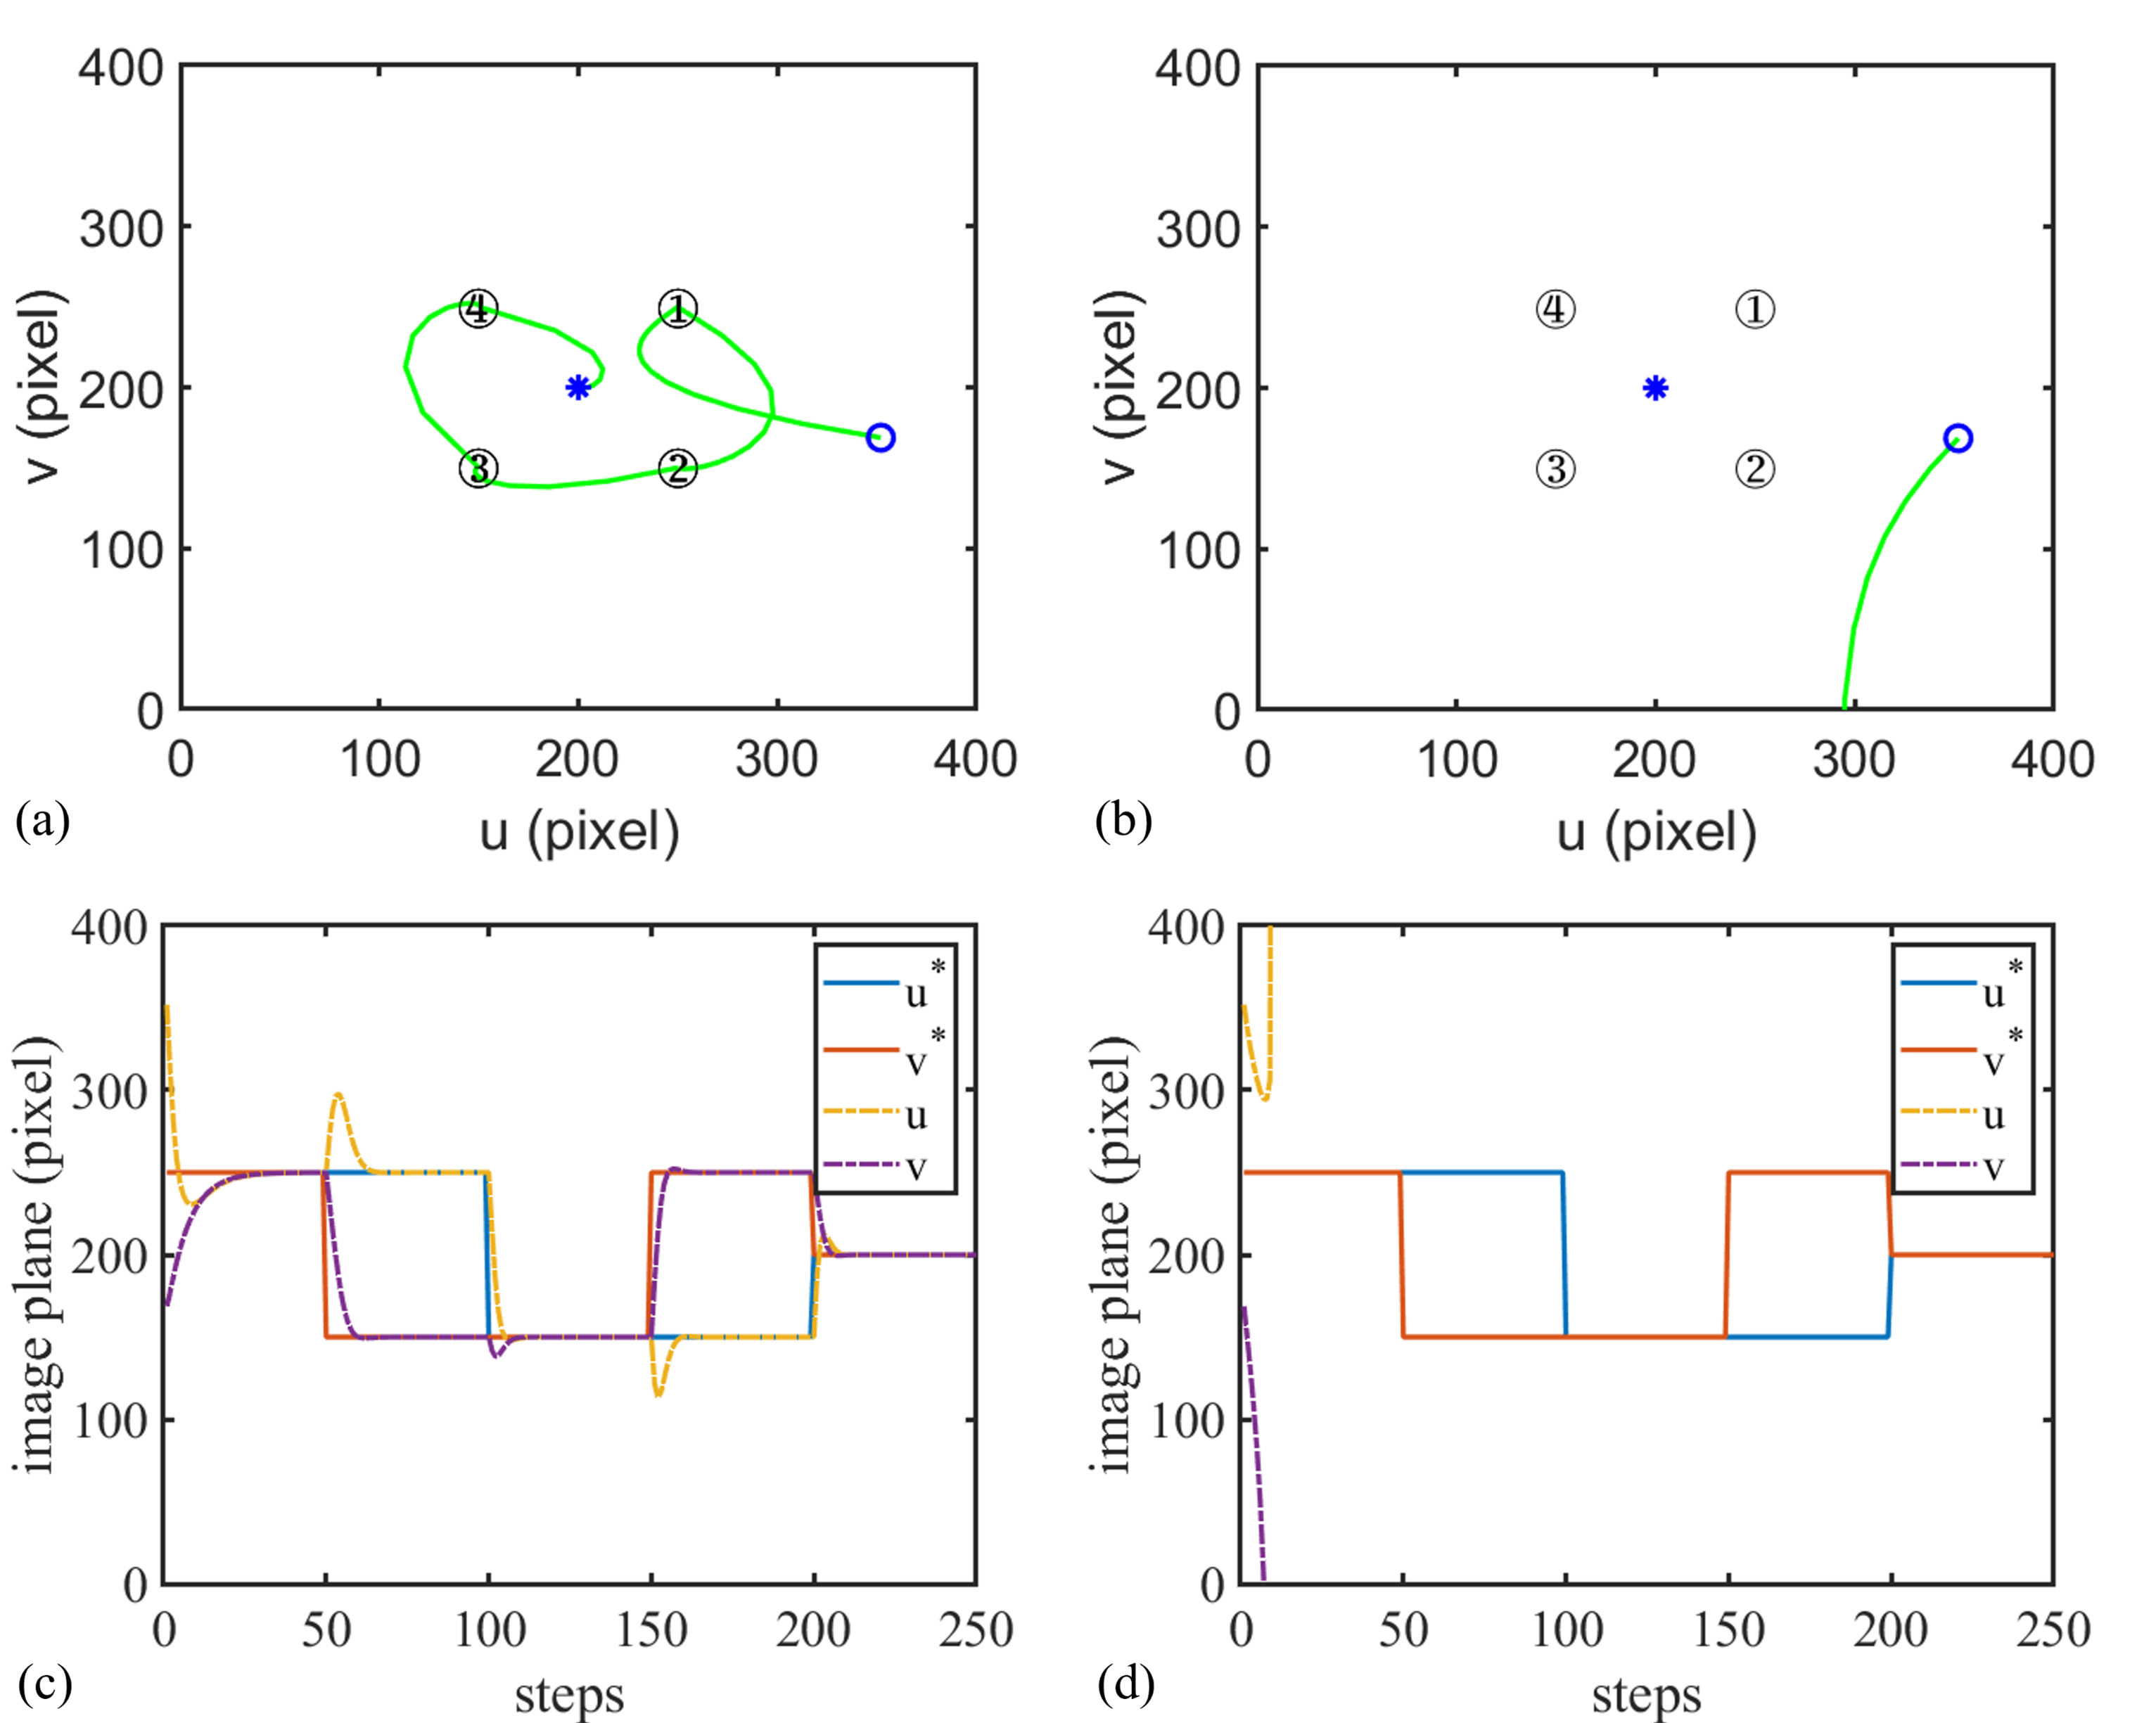
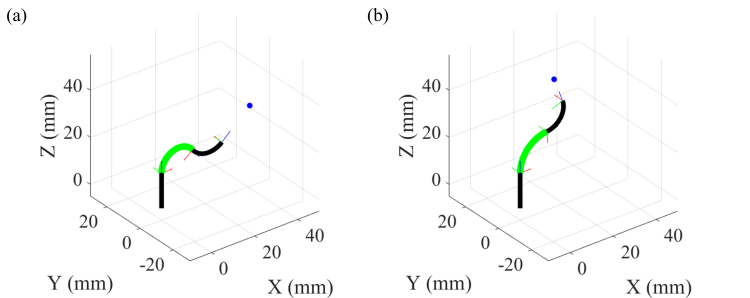
Simulation results of flexible robot control. The first figure shows the three-DoFs flexible robot, and the second one shows the two-DoFs flexible robot. For each case, we compare the image trajectory and image error obtained by the proposed method and the classical model-based approach, demonstrating improved tracking accuracy and robustness under unknown environmental constraints.
Citation
@INPROCEEDINGS{11139652,
  author    = {Chen, Wei and Wu, Haiwen and Yang, Bohan and Hu, Jinfei and Liu, Yun-Hui},
  title     = {Adaptive Vision-Based Control for Flexible Robot with Unknown Environmental Constraints},
  booktitle = {2025 IEEE International Conference on Real-time Computing and Robotics (RCAR)},
  pages     = {745--750},
  year      = {2025},
  doi       = {10.1109/RCAR65431.2025.11139652}
}