Model-Free 3-D Shape Control of Deformable Objects Using Novel Features Based on Modal Analysis
IEEE Transactions on Robotics, 2023
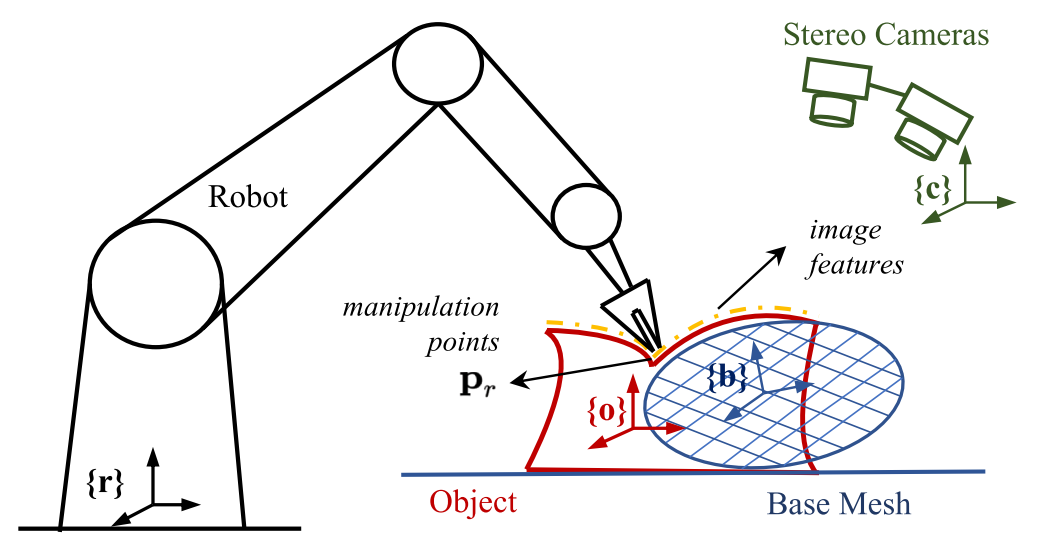
Abstract
This paper presents a model-free framework for three-dimensional shape control of deformable objects using novel features derived from modal analysis. By exploiting intrinsic deformation modes, the proposed approach enables effective visual servoing without requiring explicit physical models of the deformable object. Experimental results on deformable object manipulation tasks demonstrate accurate shape regulation, robustness to modeling uncertainties, and improved control performance compared to conventional model-based methods.
Main Contributions
- Model-free 3-D shape control framework for deformable objects
- Novel modal-analysis-based features for visual servoing
- Extensive experimental validation on deformable object manipulation
Citation
@ARTICLE{10122176,
  author  = {Yang, Bohan and Lu, Bo and Chen, Wei and
             Zhong, Fangxun and Liu, Yun-Hui},
  title   = {Model-Free 3-D Shape Control of Deformable Objects Using Novel Features Based on Modal Analysis},
  journal = {IEEE Transactions on Robotics},
  volume  = {39},
  number  = {4},
  pages   = {3134--3153},
  year    = {2023},
  doi     = {10.1109/TRO.2023.3269347}
}