Contact Us
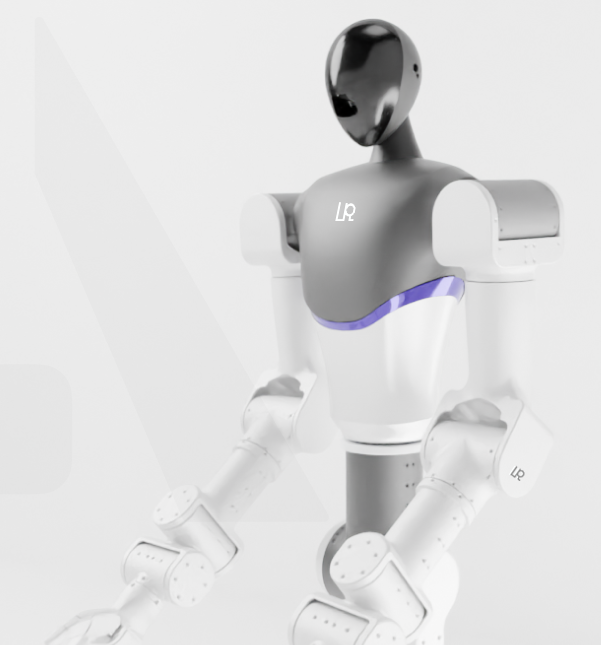
We are the Manipulation Group at the Hong Kong Centre for Logistics Robotics (HKCLR),
CUHK T Stone Robotics Institute.
Our research focuses on vision-based robotic manipulation, embodied intelligence,
and learning-based control for real-world robotic systems.
Feel free to reach out or visit our lab.
Vision-Based Manipulation
Visual servoing
Deformable object manipulation
Flexible and adaptive robot control
AI & Representation
Embodied AI
Vision-Language Models (VLM)
Vision-Language-Action (VLA)
Control & Learning
Model-based control
Model-free control
Learning-based manipulation