Intuitive Teleoperation Control for Flexible Robotic Endoscopes Under Unknown Environmental Interferences
Abstract
Teleoperation control plays a pivotal role in robot-assisted endoscopic surgery,
particularly for flexible robotic endoscopes operating in unstructured and
contact-rich environments.
Unlike conventional rigid laparoscopic systems, flexible endoscopes suffer from
severe eye–head coordination issues caused by large bending, motion coupling,
and unknown environmental interferences.
This paper proposes an intuitive teleoperation control framework that enables
field-of-view (FOV) manipulation consistent with surgeons’ intuition.
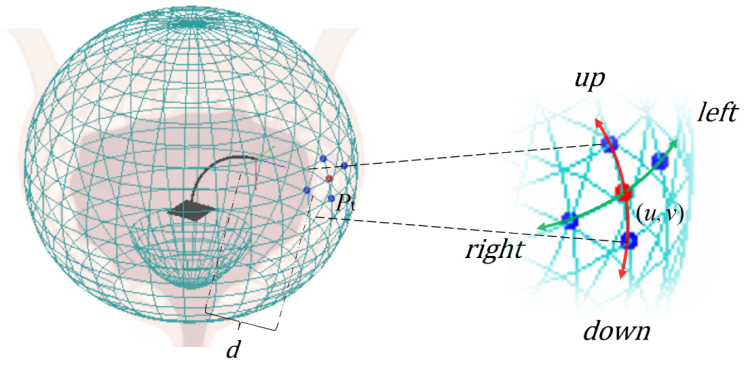
A virtual workspace is constructed to map master inputs directly to FOV motion,
eliminating the need for explicit hand–eye coordination.
To enhance robustness against unknown disturbances, accurate shape and distal pose
feedback obtained from embedded multi-core fiber Bragg grating (FBG) sensors is
integrated into an iterative constraint compliant control (ICCC) algorithm.
The proposed framework is validated on a robotic flexible ureteroscopy system with
large deflection (up to 270° bending).
Experimental results demonstrate improved trajectory tracking accuracy, disturbance
resistance, and operational intuitiveness compared with conventional configuration
space control methods.
Method Overview
- An intuitive teleoperation control framework for flexible robotic endoscopes that directly maps master motion to field-of-view (FOV) control using a virtual workspace.
- An iterative constraint compliant control (ICCC) algorithm that leverages FBG-based shape and pose sensing to robustly handle unknown environmental interferences.
- Robust shape sensing and disturbance-resistant control validated on a robotic flexible ureteroscopy system with large bending angles and strong environmental interactions.
Results


Citation
@INPROCEEDINGS{10591885,
  author    = {Chen, Wei and Lu, Yiang and Li, Bin and Zhou, Jianshu and Cao, Hanwen and Chen, Fei and Liu, Yun-Hui},
  title     = {Intuitive Teleoperation Control for Flexible Robotic Endoscopes Under Unknown Environmental Interferences},
  booktitle = {2024 IEEE 18th International Conference on Control & Automation (ICCA)},
  pages     = {24--29},
  year      = {2024},
  doi       = {10.1109/ICCA62789.2024.10591885}
}