Tele-Operated Oropharyngeal Swab (TOOS) Robot Enabled by TSS Soft Hand for Safe and Effective Sampling
IEEE Transactions on Medical Robotics and Bionics, 2021
Abstract
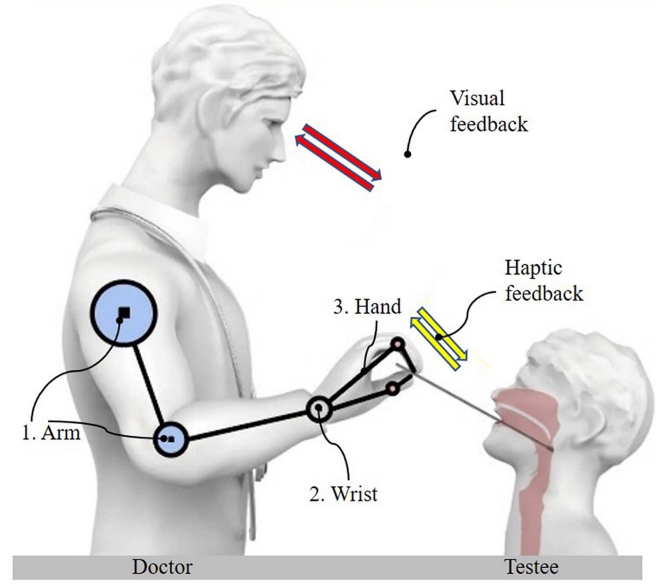
This paper presents a tele-operated oropharyngeal swab (TOOS) robot designed for safe and effective COVID‑19 sampling. The system integrates a TSS soft robotic hand with a teleoperation framework to enable compliant and precise swab manipulation in the oropharyngeal region. By combining soft robotic grasping, force sensing, and real-time teleoperation, the TOOS robot significantly reduces cross‑infection risk to healthcare workers while maintaining reliable sampling performance.
Main Contributions
- Tele-operated robotic system for safe oropharyngeal swab sampling
- Integration of TSS soft hand for compliant and safe interaction
- Experimental validation in medical and clinical scenarios
Citation
@ARTICLE{9590555,
  author  = {Chen, Wei and Zhou, Jianshu and Cheng, Shing Shin and Lu, Yiang and
             Zhong, Fangxun and Gao, Yuan and Wang, Yaqing and Xue, Lingbin and
             Tong, Michael C. F. and Liu, Yun-Hui},
  title   = {Tele-Operated Oropharyngeal Swab (TOOS) Robot Enabled by TSS Soft Hand
             for Safe and Effective Sampling},
  journal = {IEEE Transactions on Medical Robotics and Bionics},
  volume  = {3},
  number  = {4},
  pages   = {1040--1053},
  year    = {2021},
  doi     = {10.1109/TMRB.2021.3123530}
}