A Robotic Skin Using Low-density FBGs for Human-robot Interaction
IEEE International Conference on Robotics and Biomimetics (ROBIO), 2024
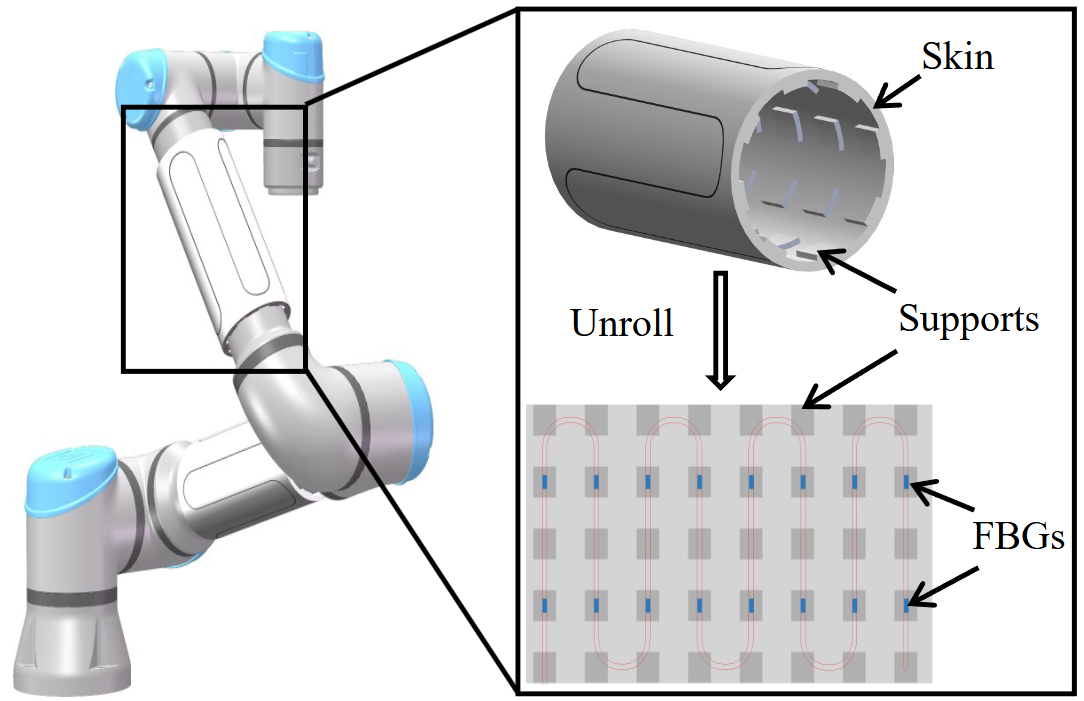
Abstract
This paper presents a robotic skin system based on low-density fiber Bragg gratings (FBGs) for human–robot interaction. By strategically deploying a sparse array of FBG sensors, the proposed skin accurately perceives contact force and surface deformation while significantly reducing sensor density and system complexity. Experimental results demonstrate reliable force sensing and shape estimation, enabling safe and responsive interaction in soft robotic and collaborative systems.
Main Contributions
- Low-density FBG-based robotic skin design
- Accurate force and shape sensing with reduced sensor complexity
- Experimental validation for human–robot interaction scenarios
Citation
@INPROCEEDINGS{10907681,
  author    = {Dong, Xiyue and Lam, Chin-Kiu and Chen, Wei and
               Yang, Bohan and Liu, Yun-Hui},
  title     = {A Robotic Skin Using Low-density FBGs for Human-robot Interaction},
  booktitle = {2024 IEEE International Conference on Robotics and Biomimetics (ROBIO)},
  pages     = {129--134},
  year      = {2024},
  doi       = {10.1109/ROBIO64047.2024.10907681}
}