Adaptive FOV Control of Laparoscopes with Programmable Composed Constraints
IEEE Transactions on Medical Robotics and Bionics, 2019
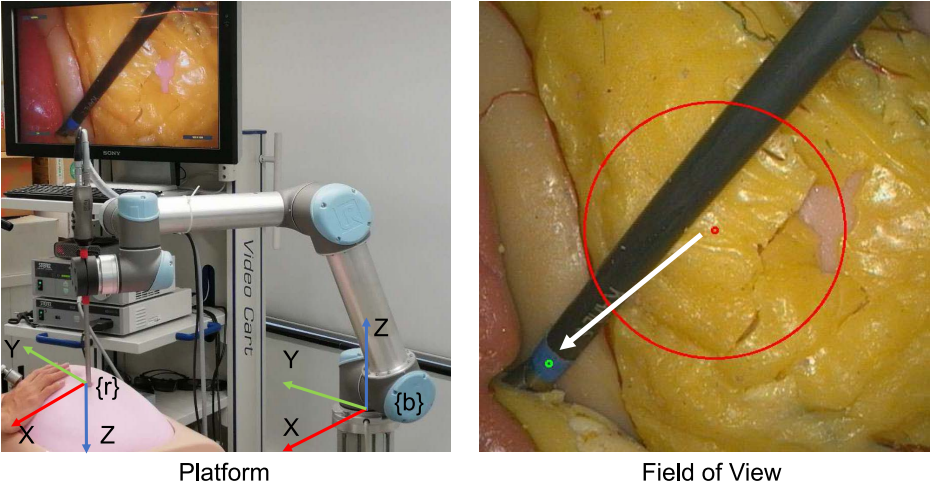
Abstract
This paper presents an adaptive field-of-view (FOV) control framework for robotic laparoscopic systems based on programmable composed constraints. The proposed approach integrates region-based image-based visual servoing (IBVS) with remote center of motion (RCM) and intuitive virtual plane (IVP) constraints, leading to improved visual stability, safety, and eye–hand coordination in minimally invasive surgery.
Method Overview
The proposed controller decouples the image-based visual servoing task and constraint enforcement using a null-space formulation, allowing extension to laparoscopes with different optical axis configurations.
Video Demonstration
Demonstration of automatic laparoscope manipulation with adaptive FOV control under RCM–IVP constraints.
Main Contributions
- Adaptive region-based IBVS for robotic laparoscope FOV control
- Programmable composed constraints integrating RCM and IVP
- Online estimation of depth-related parameters
- Extensive experimental validation and user studies
Citation
@article{yang2019adaptive,
  title     = {Adaptive FOV Control of Laparoscopes with Programmable Composed Constraints},
  author    = {Yang, Bohan and Chen, Wei and Wang, Zerui and Lu, Yiang and
               Mao, Jiayue and Wang, Hesheng and Liu, Yun-Hui},
  journal   = {IEEE Transactions on Medical Robotics and Bionics},
  volume    = {1},
  number    = {4},
  pages     = {206--217},
  year      = {2019},
  publisher = {IEEE}
}