Research
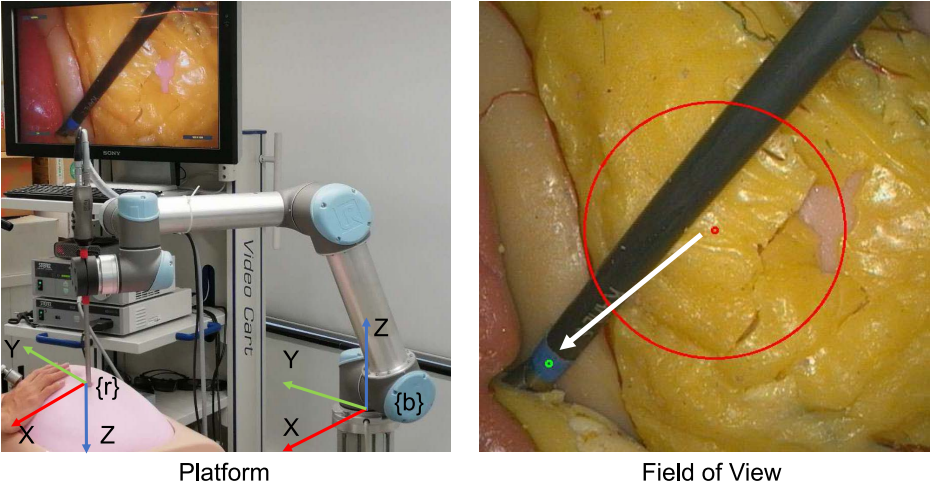
Our research focuses on vision-based robotic manipulation, embodied AI, and learning-based control for real-world robotic systems. We aim to develop robotic systems that can perceive, reason, and interact robustly with complex and unstructured environments.
Highlighted
All
2025
2024
2023
2022
2021
2019