Biography
Wei Chen received the M.S. and Ph.D. degrees in Mechanical and Automation Engineering from The Chinese University of Hong Kong (CUHK), Hong Kong, in 2021 and 2025, respectively. He is currently a Postdoctoral Fellow at the Hong Kong Centre for Logistics Robotics (HKCLR) and the CUHK T Stone Robotics Institute (CURI), Hong Kong SAR, where he leads the Manipulation Group, focusing on the development of robotic manipulation platforms and algorithms for embodied AI and robotic control. His research interests include medical robotics, soft and continuum robotics, and embodied AI.
Publications
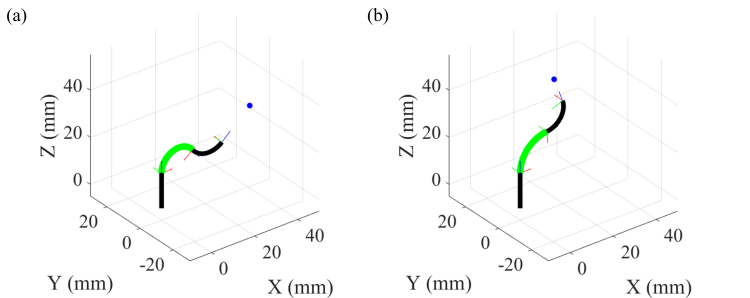
Adaptive Vision-Based Control for Flexible Robot with Unknown Environmental Constraints
IEEE International Conference on Real-time Computing and Robotics (RCAR)
·
01 Jan 2025
·
doi:10.1109/RCAR65431.2025.11139652
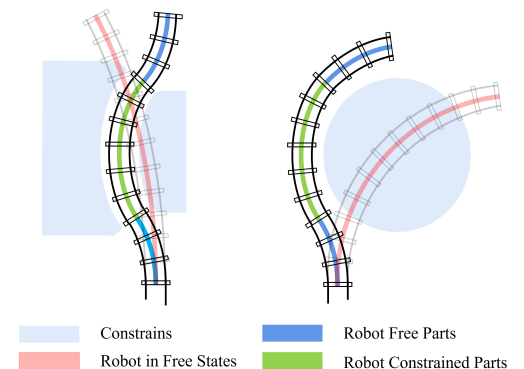
Data-driven Visual Servoing of Flexible Continuum Robots in Constrained Environments
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
·
25 Sep 2025
·
doi:10.1109/IROS60139.2025.11246163
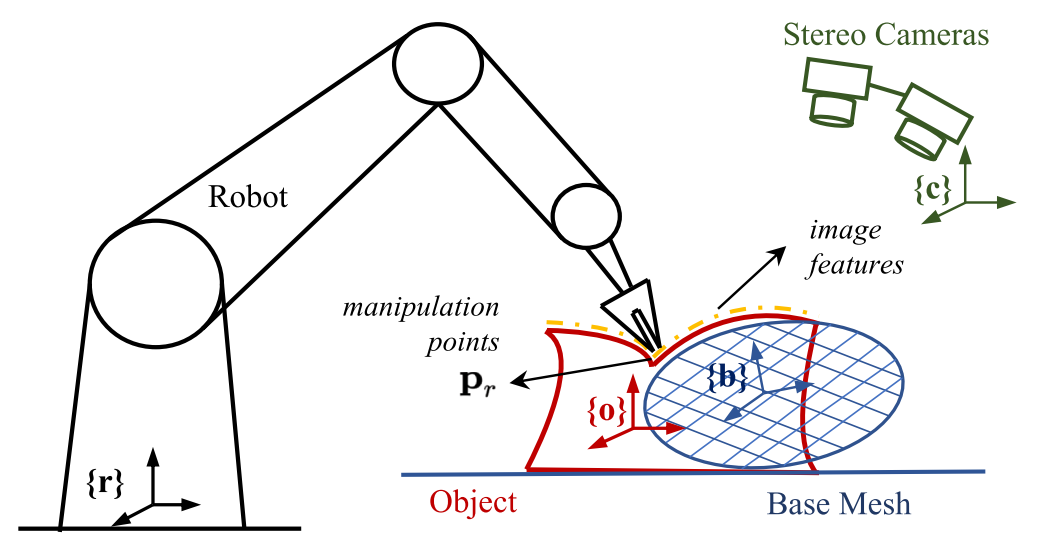
Model-Free 3-D Shape Control of Deformable Objects Using Novel Features Based on Modal Analysis
IEEE Transactions on Robotics
·
01 Aug 2023
·
doi:10.1109/TRO.2023.3269347
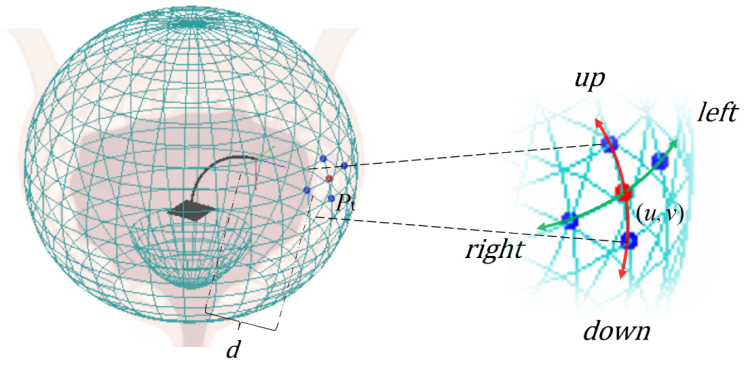
Intuitive Teleoperation Control for Flexible Robotic Endoscopes Under Unknown Environmental Interferences
2024 IEEE 18th International Conference on Control & Automation (ICCA)
·
01 Jun 2024
·
doi:10.1109/ICCA62789.2024.10591885
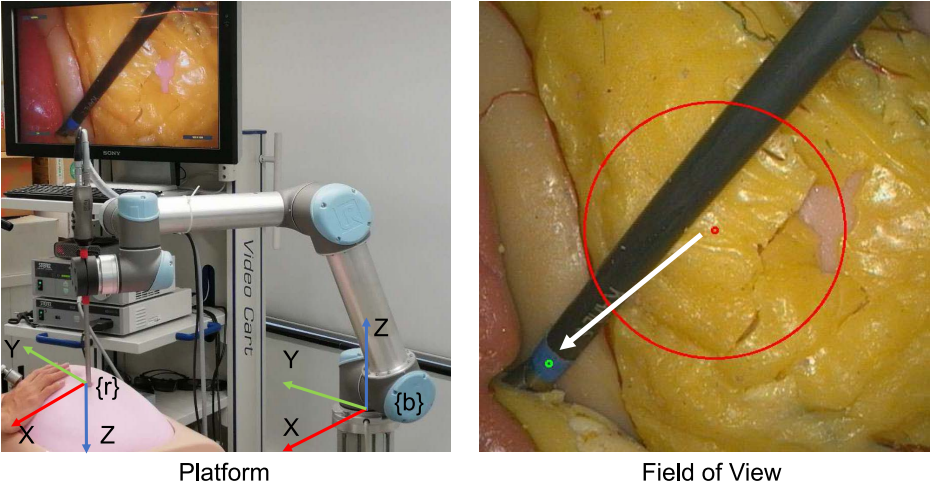
Adaptive FOV Control of Laparoscopes with Programmable Composed Constraints
IEEE Transactions on Medical Robotics and Bionics
·
01 Nov 2019
·
doi:10.1109/TMRB.2019.2949881
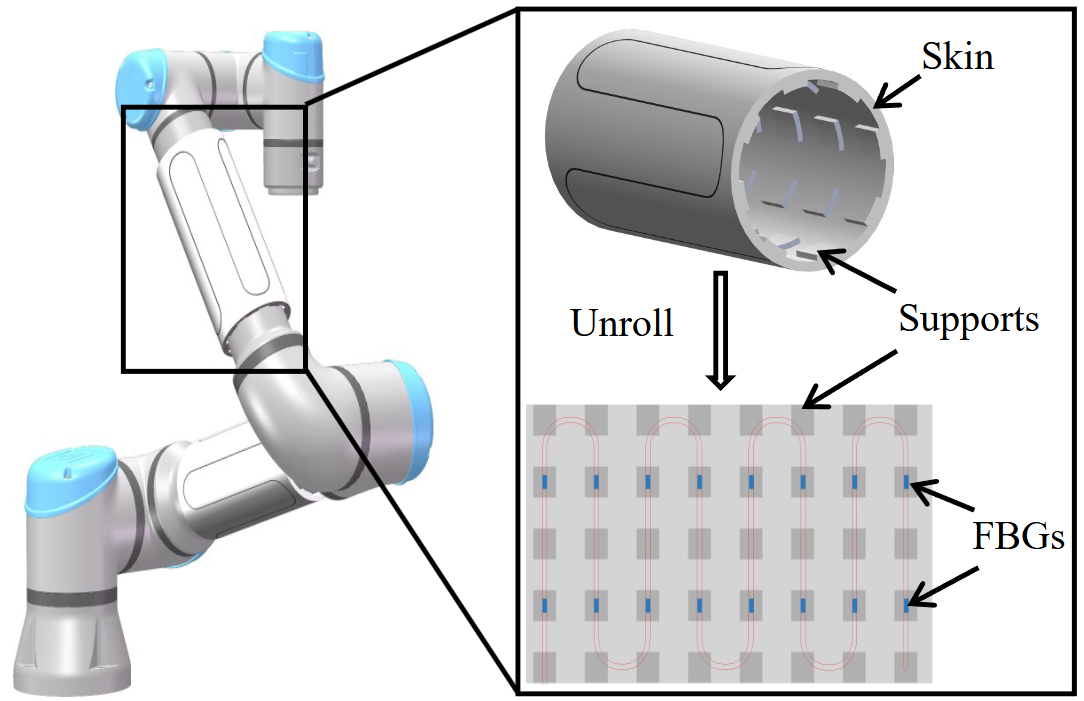
A Robotic Skin Using Low-density FBGs for Human-robot Interaction
IEEE International Conference on Robotics and Biomimetics (ROBIO)
·
01 Jan 2024
·
doi:10.1109/ROBIO64047.2024.10907681
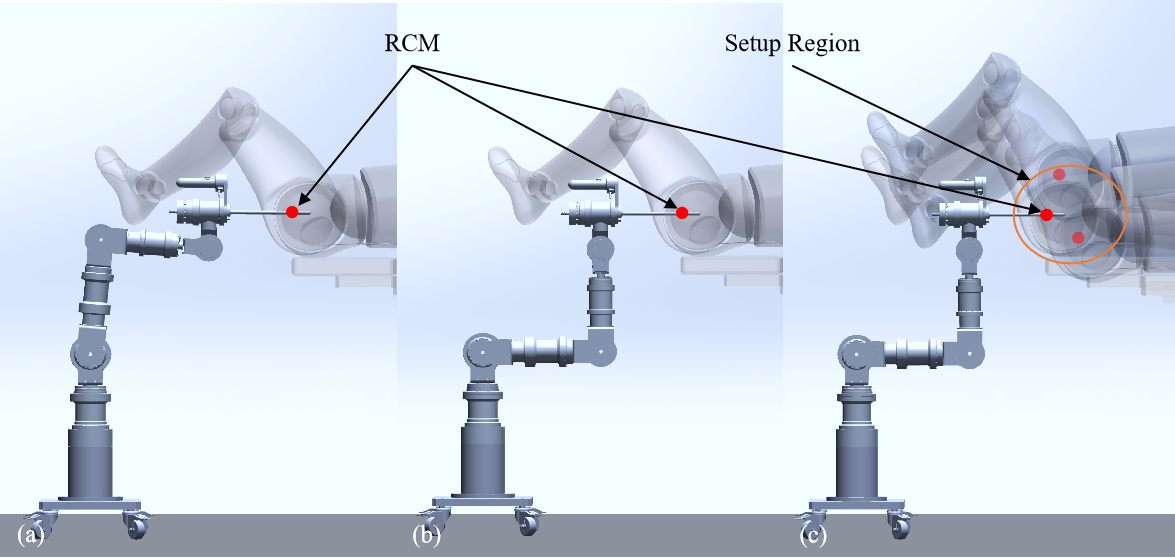
Configurability Selection of Robotic Arm with Constrained Task and Environment in Laparoscopic Hysterectomy for Uterus Manipulation
IEEE International Conference on Real-time Computing and Robotics (RCAR)
·
01 Jan 2022
·
doi:10.1109/RCAR54675.2022.9872266
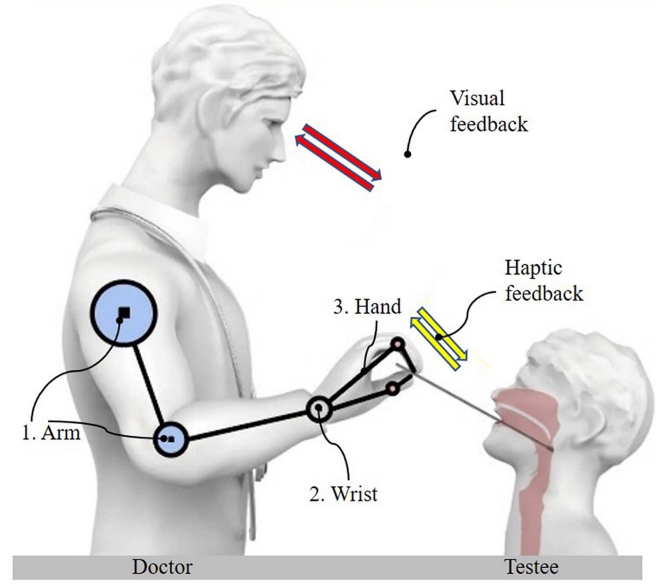
Tele-Operated Oropharyngeal Swab (TOOS) Robot Enabled by TSS Soft Hand for Safe and Effective Sampling
IEEE Transactions on Medical Robotics and Bionics
·
01 Nov 2021
·
doi:10.1109/TMRB.2021.3123530