Projects
Our projects span robotic manipulation, embodied AI, and data-driven control. We develop open-source software, hardware prototypes, and experimental platforms that translate theoretical advances into real-world robotic systems.
Featured
Highlighted projects that represent our core research directions and recent developments in robotic manipulation and medical robotics.
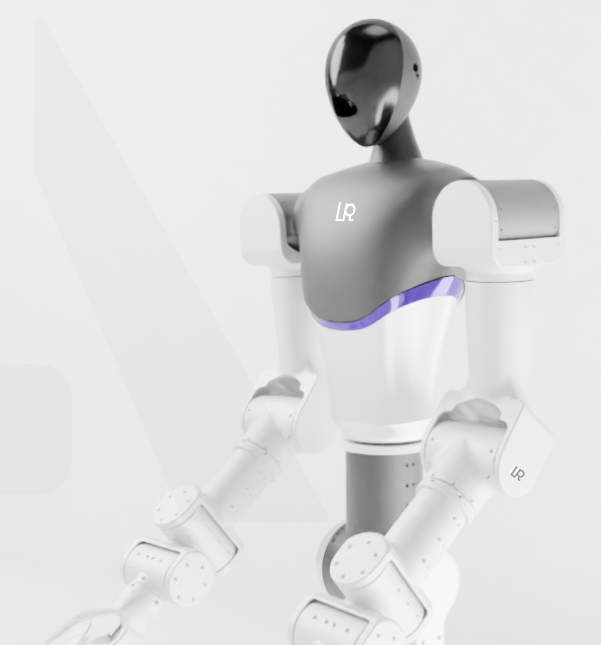
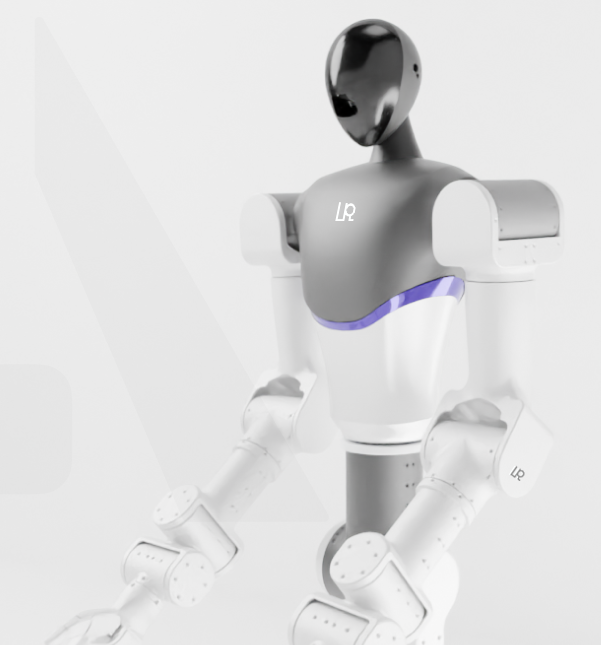
A mobile dual-arm robotic platform designed for coordinated bimanual manipulation. The system integrates a lightweight mobile base with two collaborative robotic arms, enabling robust and dexterous manipulation in unstructured and dynamic environments.
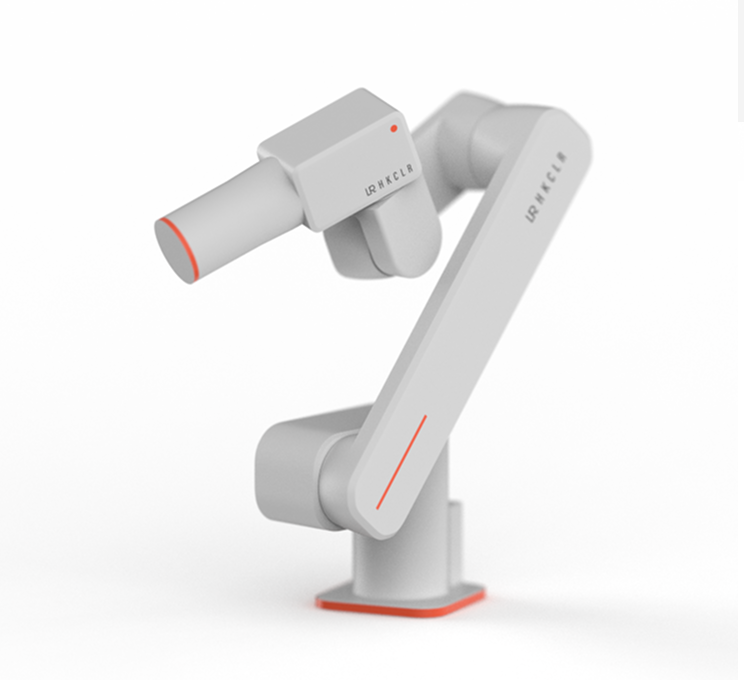
A lightweight robotic arm optimized for mobile manipulation scenarios. The arm features a high payload-to-weight ratio, compliant actuation, and intrinsic safety, making it suitable for service, logistics, and medical robotic applications.
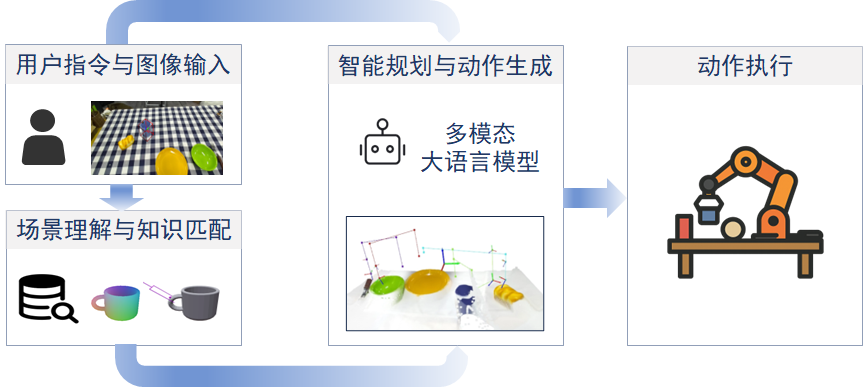
An embodied AI framework that integrates vision–language models (VLMs) for high-level task understanding and long-horizon planning, together with vision–language–action (VLA) policies for dynamic interaction. The framework bridges semantic reasoning and low-level robot control for dual-arm manipulation tasks.
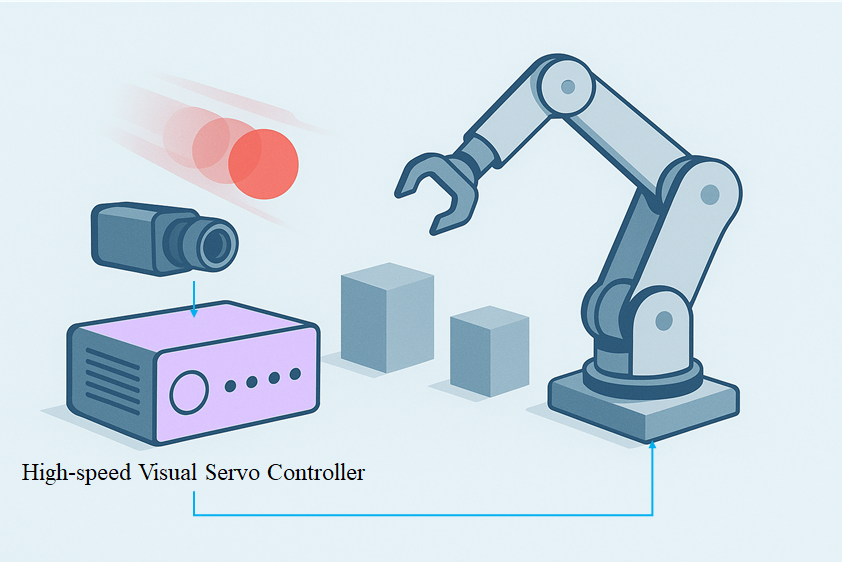
A high-speed visual servoing framework for real-time robotic control in dynamic and uncertain environments. The approach emphasizes low-latency perception, adaptive Jacobian estimation, and closed-loop stability for precision manipulation tasks.
More
Additional projects, tools, and experimental platforms developed by the group.