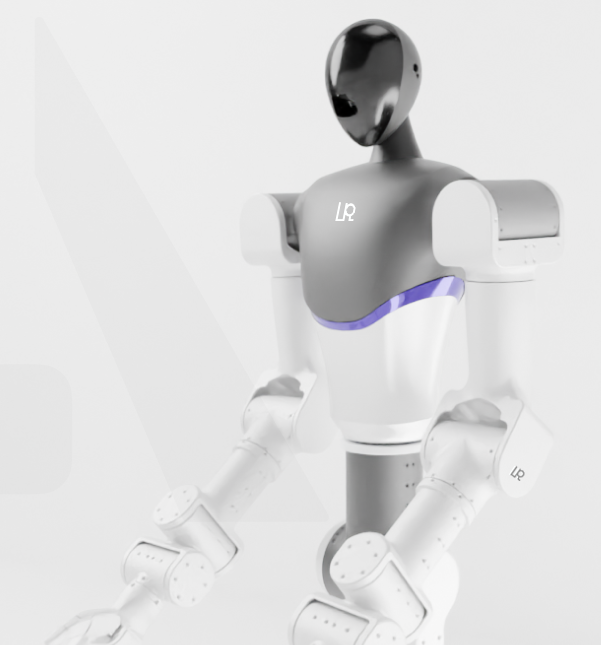
Blog
Welcome to the blog of the Manipulation Group at the Hong Kong Centre for Logistics Robotics (HKCLR).
Our research focuses on robotic manipulation systems that bridge fundamental research and real-world deployment. We develop platforms ranging from lightweight robotic arms to mobile dual-arm systems, with an emphasis on autonomy, robustness, and deployability in unstructured, contact-rich environments.
Here we share research updates, technical notes, system design experiences, and perspectives on model-based and learning-driven manipulation, including vision–language–action approaches.
The Manipulation Group at the Hong Kong Centre for Logistics Robotics (HKCLR) is recruiting highly motivated students and researchers to join our team.